01
Feedback and control loops in servo drive design
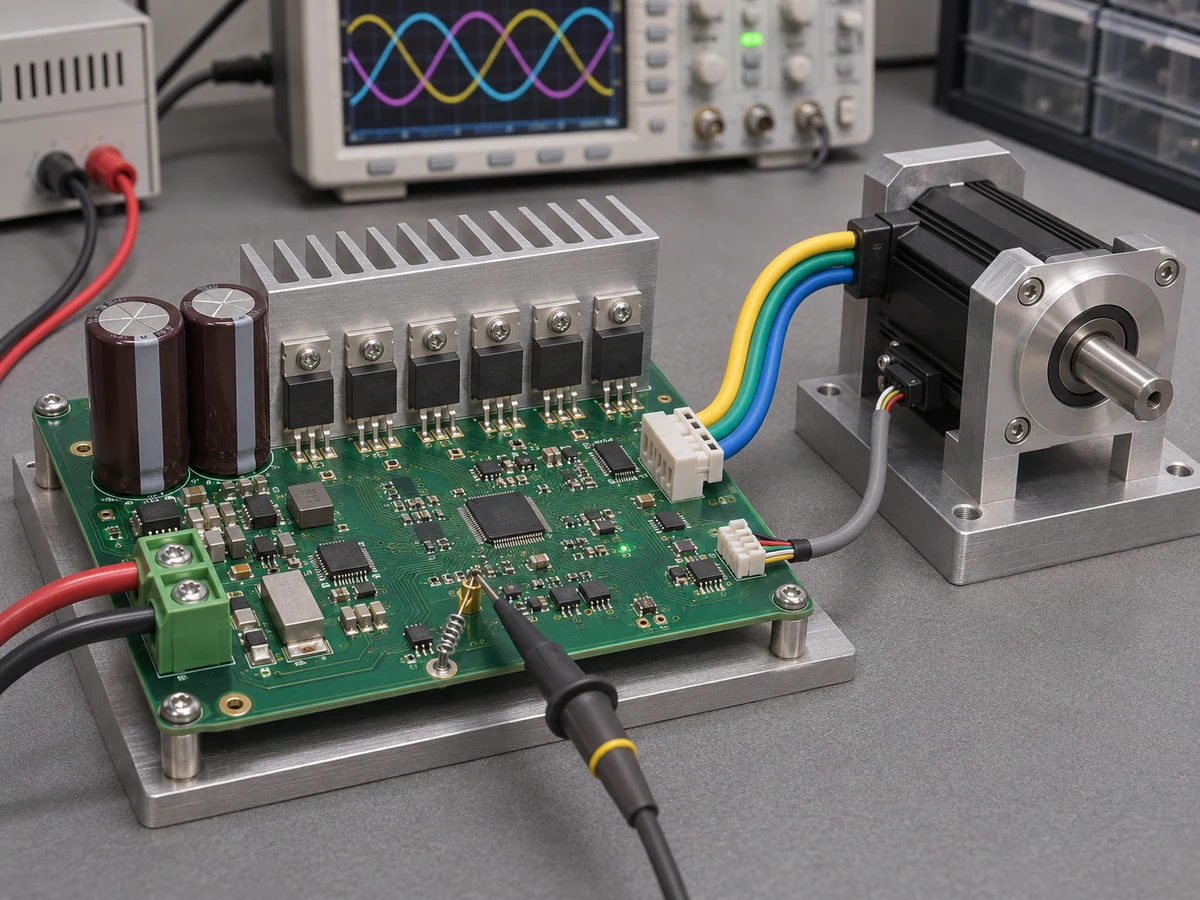
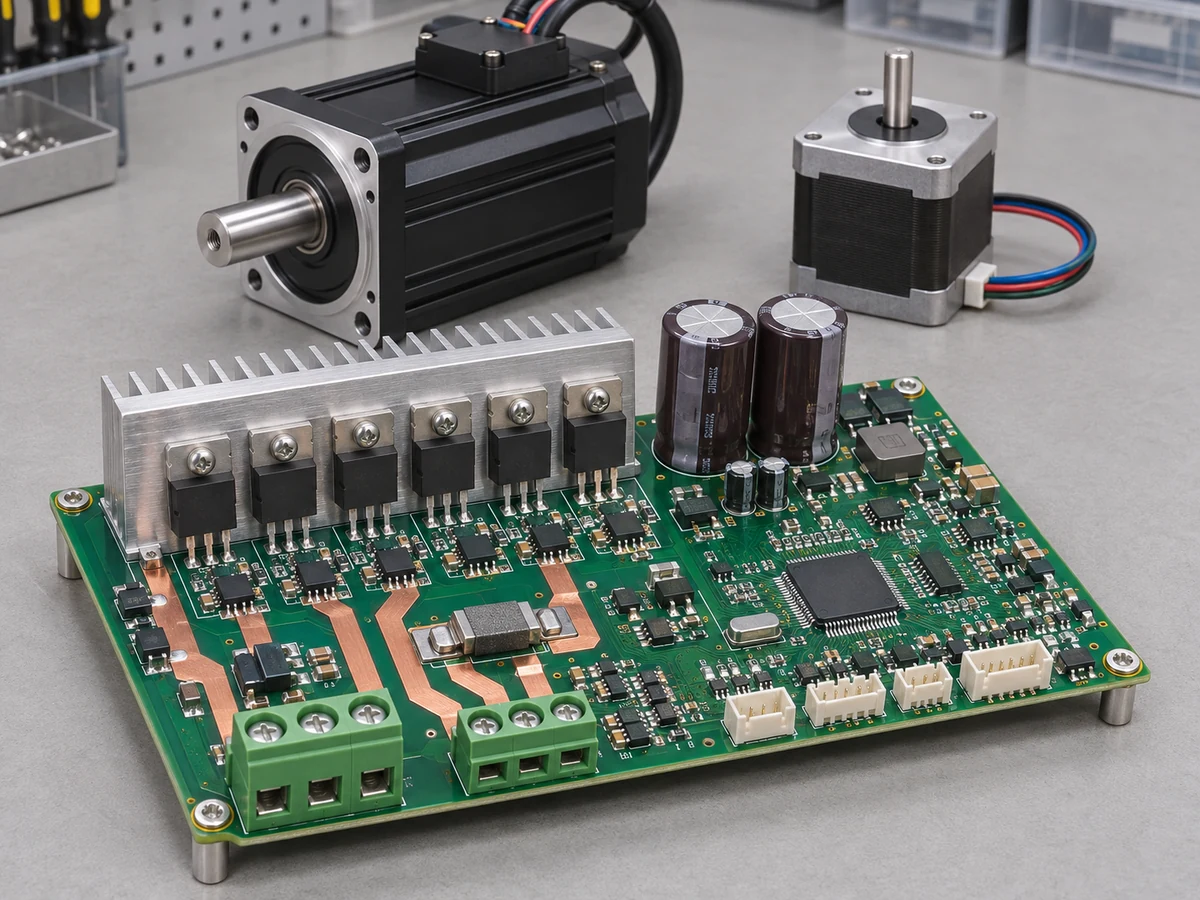
Servo does not, on its own, describe the motor’s electrical type; it describes a control architecture that regulates position, speed or torque using feedback. A suitable PMSM/BLDC or stepper motor can be used in a closed-loop system according to the task. Encoder resolution and interface, current feedback, mechanical backlash and load changes are assessed together. Current, speed and position loops are tuned and tested with the actual mechanism; spinning an unloaded motor alone does not validate an axis.